Daojie Peng

Daojie Peng

PhD Student in Robotics and Autonomous Systems | Supervisor: Prof. Jun Ma
Hong Kong University of Science and Technology (Guangzhou)

I am currently a PhD Student in Robotics and Autonomous Systems at the Hong Kong University of Science and Technology (Guangzhou). I completed my undergraduate studies at Shandong University and my postgraduate studies at Southern University of Science and Technology, which has equipped me with a solid and continuous academic foundation in engineering and intelligent robotics.

My research focuses on embodied intelligence, robotic perception and control, vision-language-action models, and world-action models. My specific research scope covers foundational action large models, physical AI, legged robots, humanoid robots, and cloud-edge-end collaborative systems. Committed to solving fundamental and long-term challenging problems in physical artificial intelligence, I aim to build generalizable and deployable intelligent robotic systems that adapt to real-world physical environments.
📚 Publications

arXiv
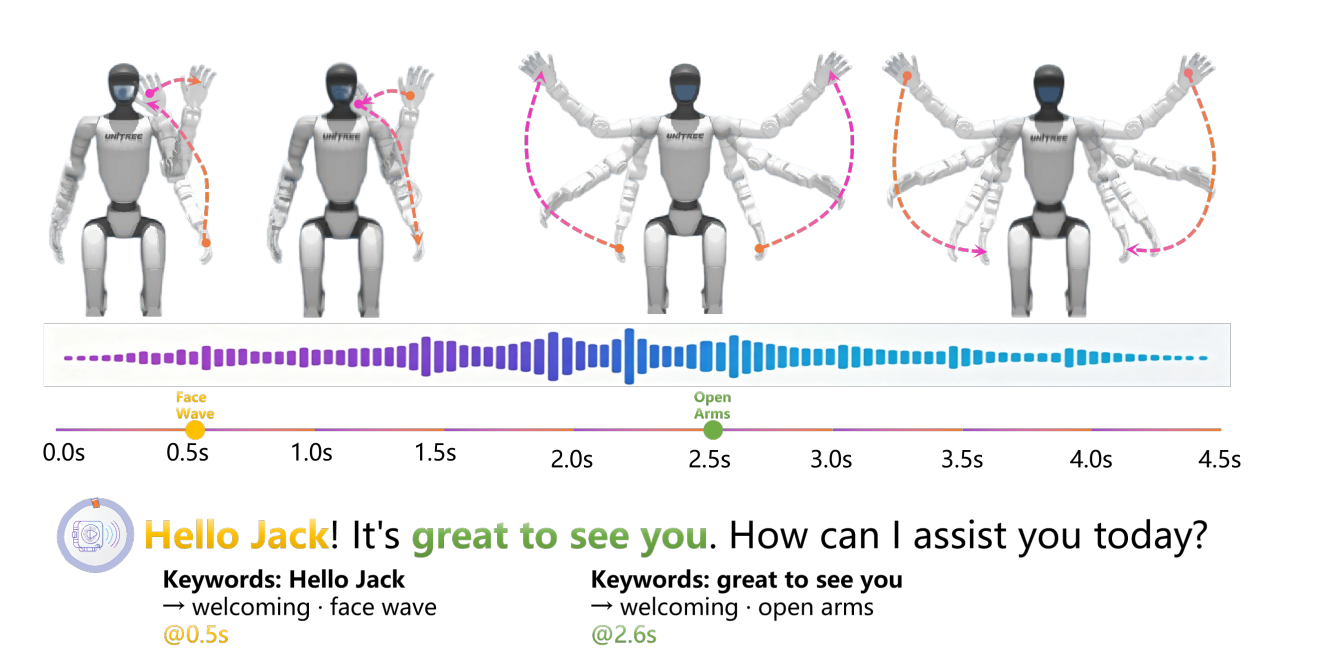
EmoPose two-gesture execution with library trajectories and lexical release timeline
📝 arXiv 2026 🔓 Preprint
EmoPose: Vision-Language Model Guided Emotion-Aware Gesture Generation for Humanoid Robots
Daojie Peng, Bingtao Wang, Fulong Ma, Wenjun Yue, Liang Zhang, Jun Ma
arXiv
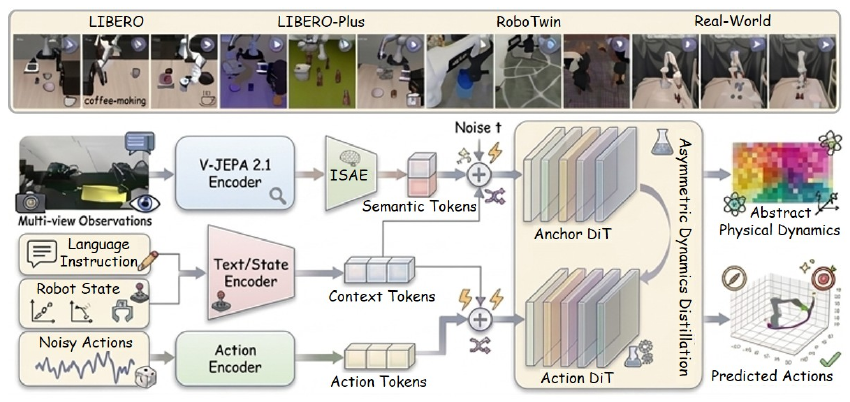
LeapBot-WA predictive world-anchor action model overview
📝 arXiv 2026 🔓 Preprint
LeapBot-WA: World-Anchor Action Models via Predictive Latent Alignments
Pei Liu, Nan Zheng, Lang Zhang, Daojie Peng, Yanan Zhang, Feilong Kong, Mingyue Feng, Jiachao Liu, Yaonong Wang, Qifeng Chen, Jun Ma
ICLR
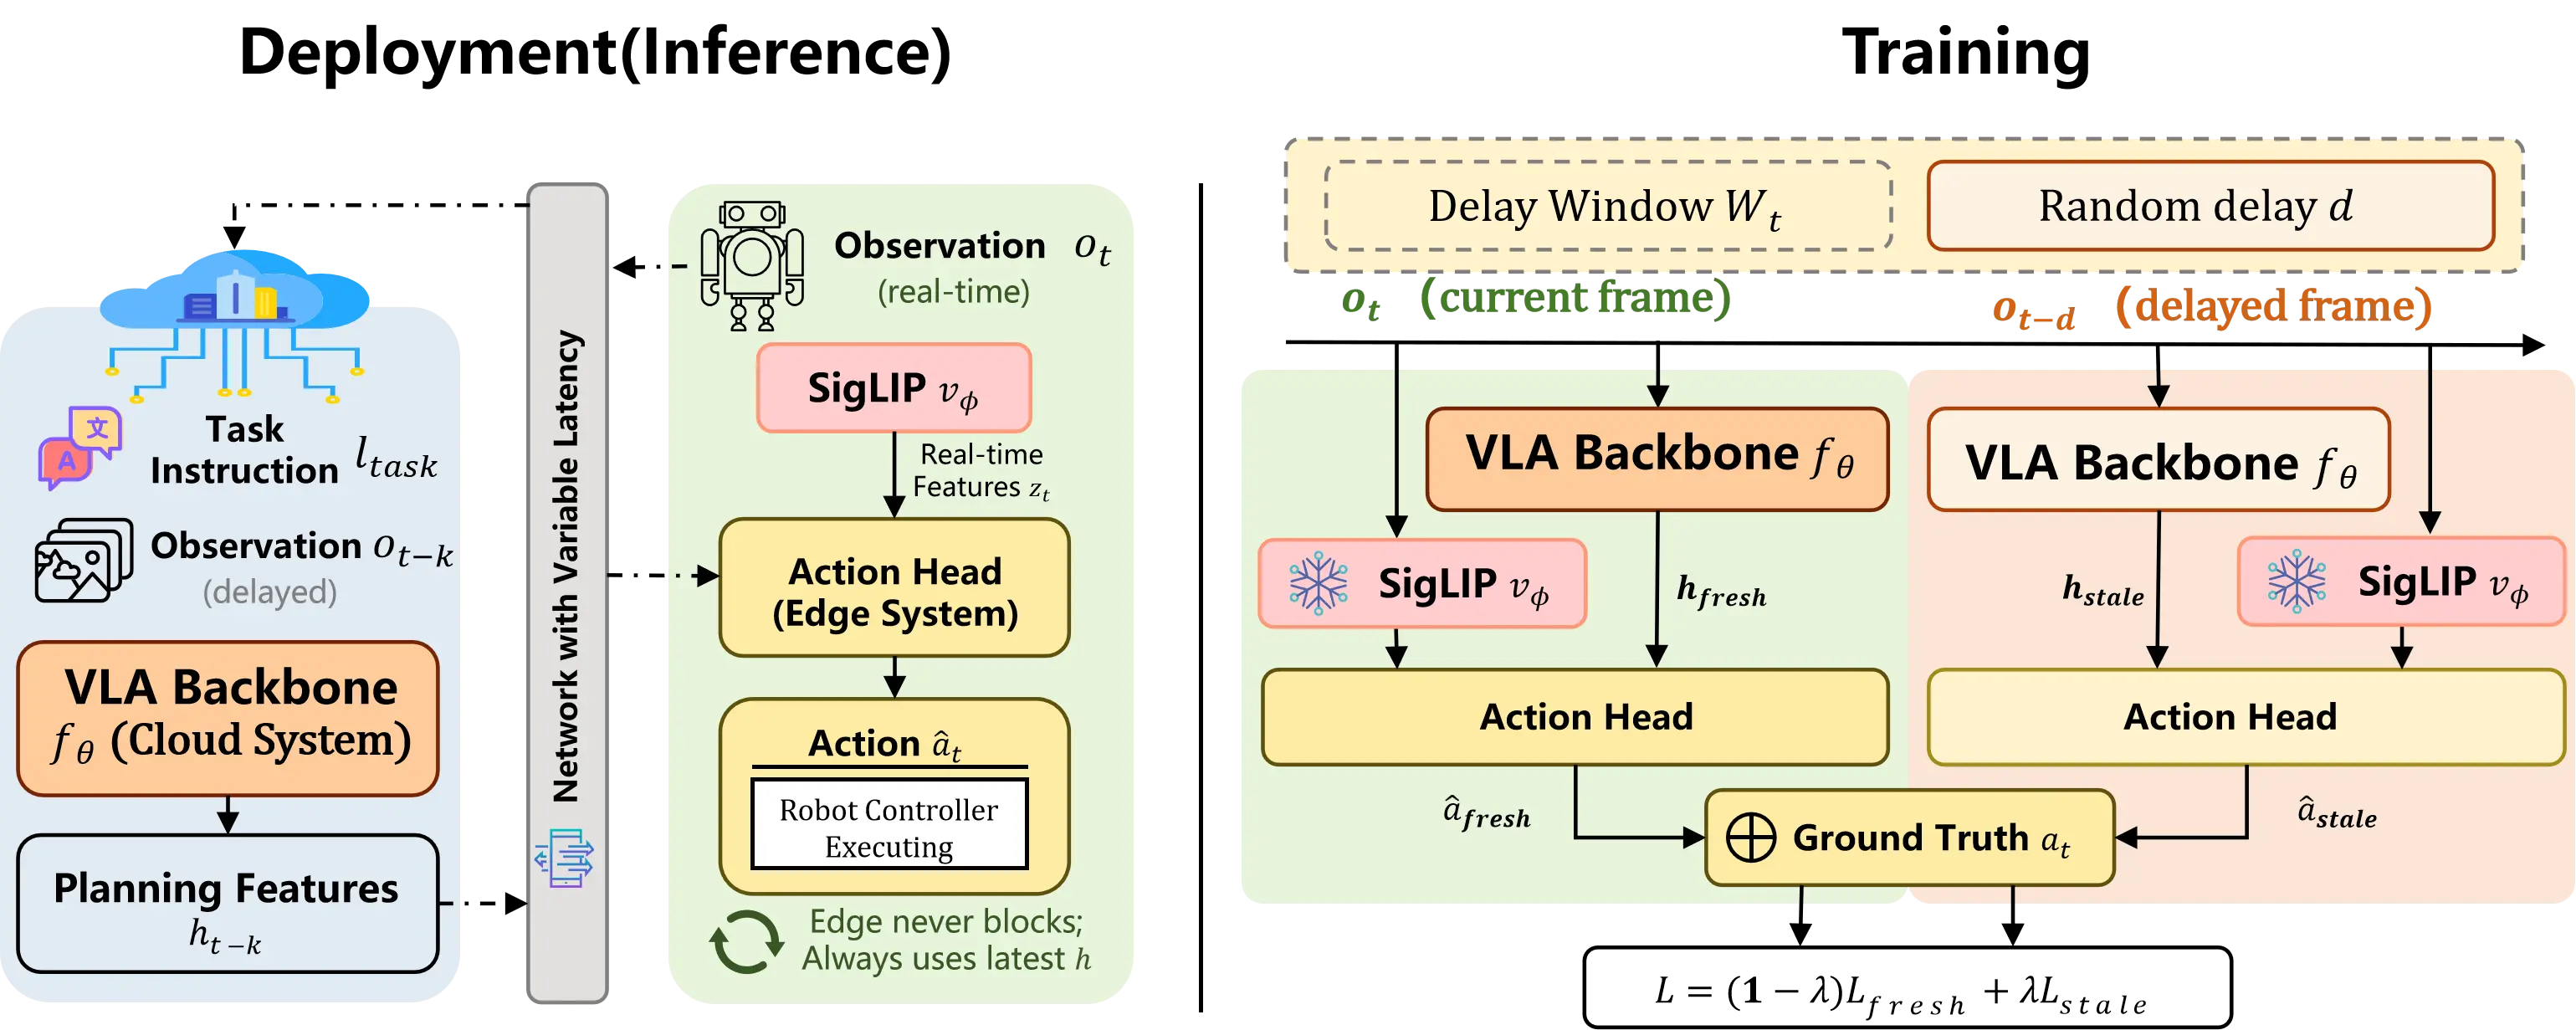
CloudEdgeVLA deployment and paired-frame training architecture
📝 ICLR 2027 🔓 Under Review
Latency-Tolerant Cloud-Edge Collaborative Vision-Language-Action Models via Emergent Representational Specialization
Daojie Peng, Fulong Ma, Bingtao Wang, Sheng Wang, Jun Ma
AAAI
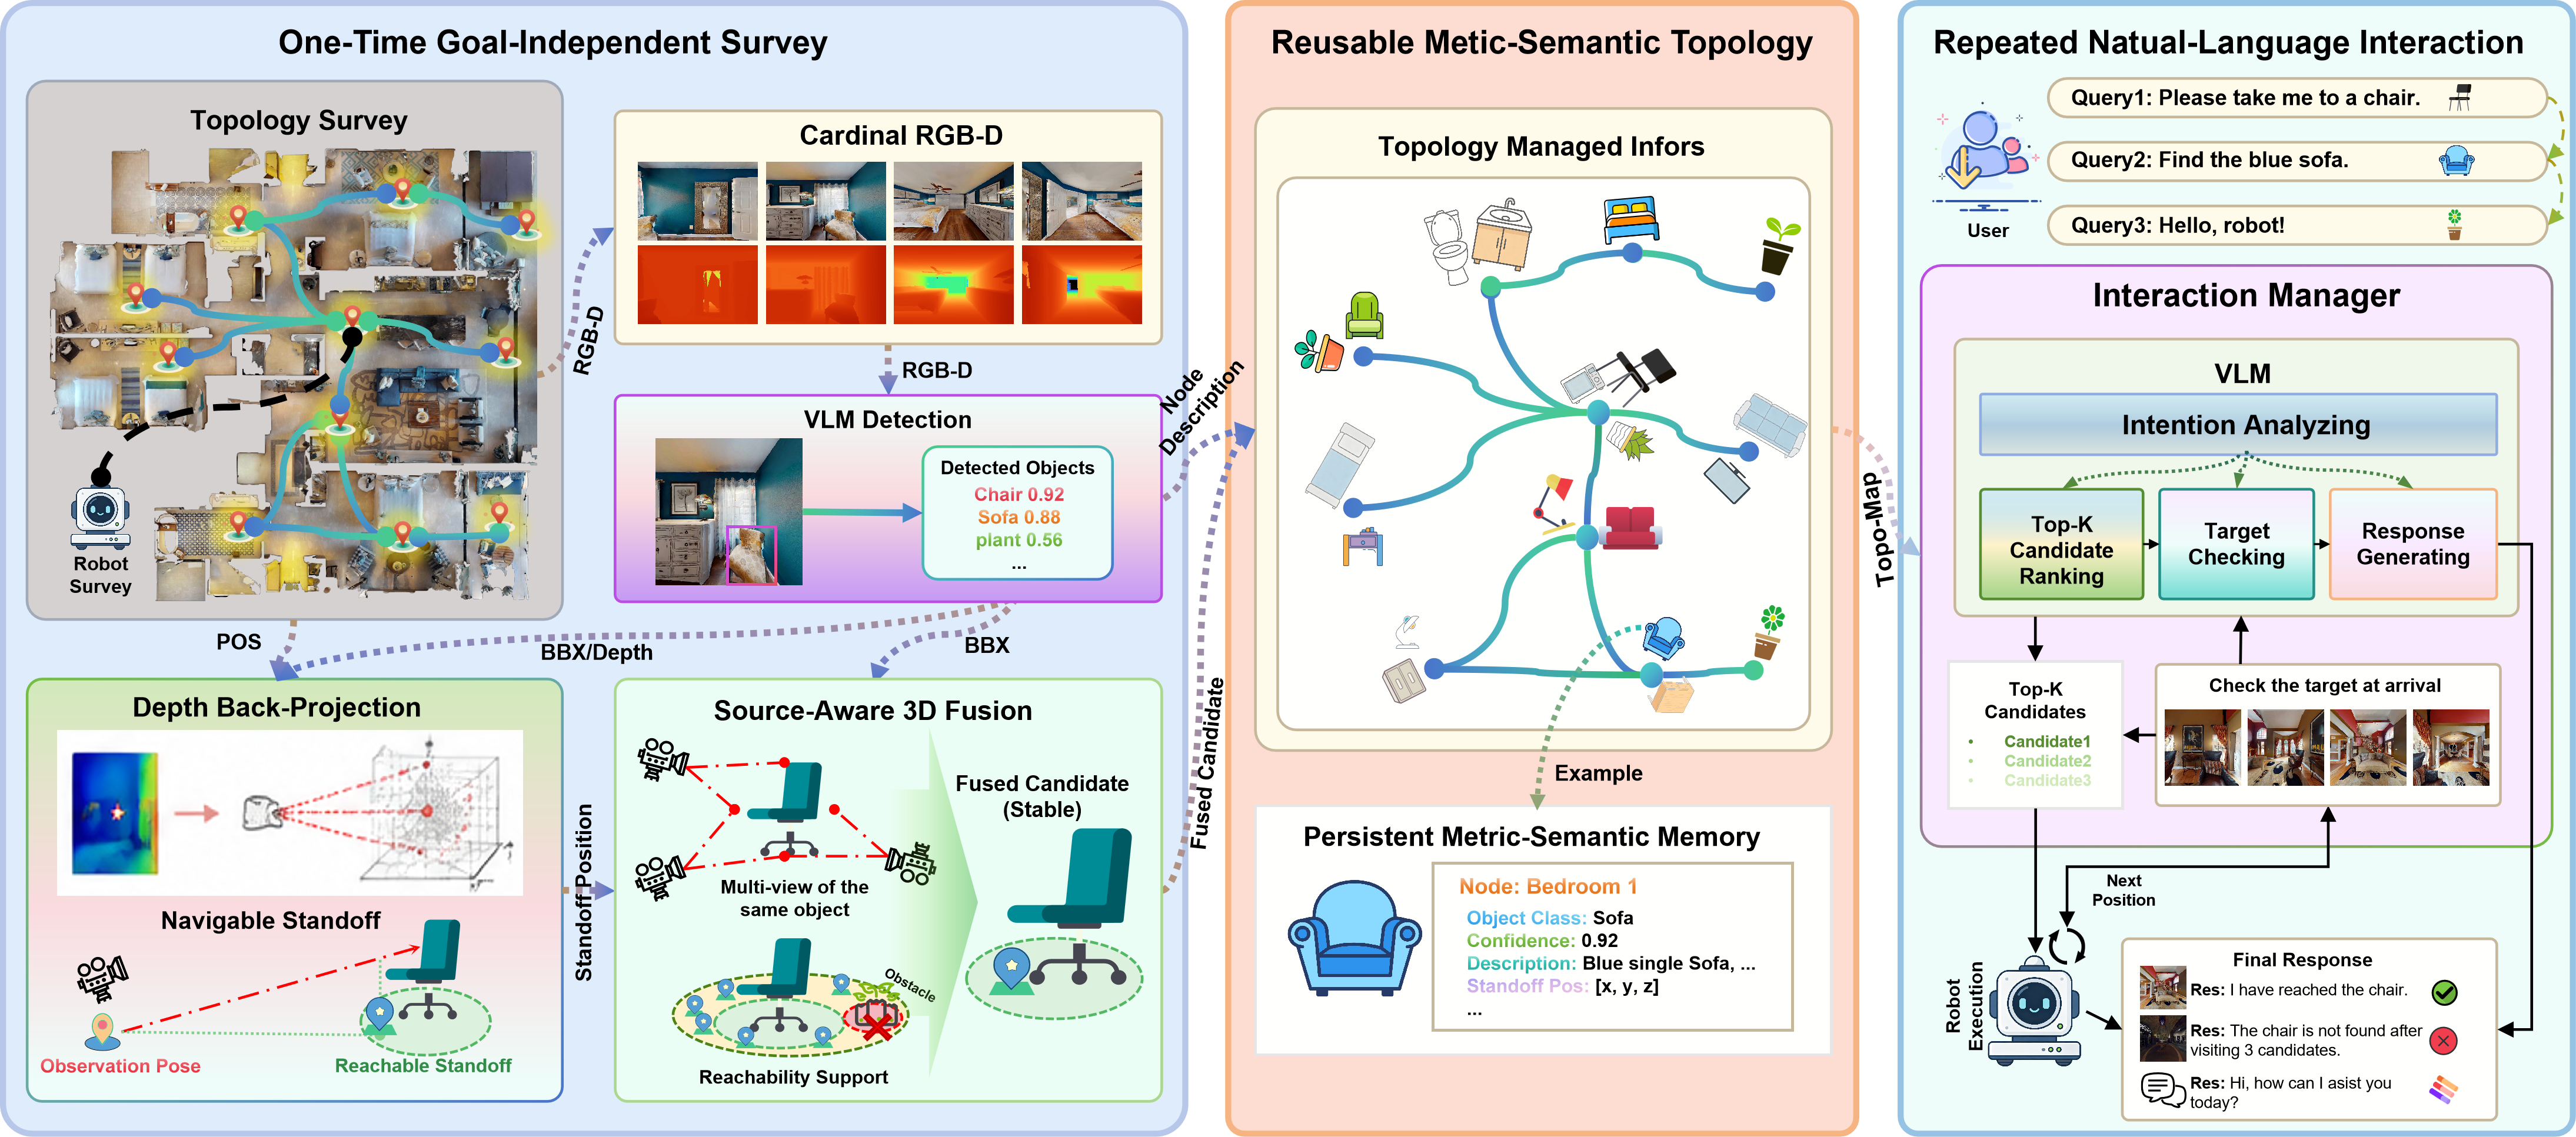
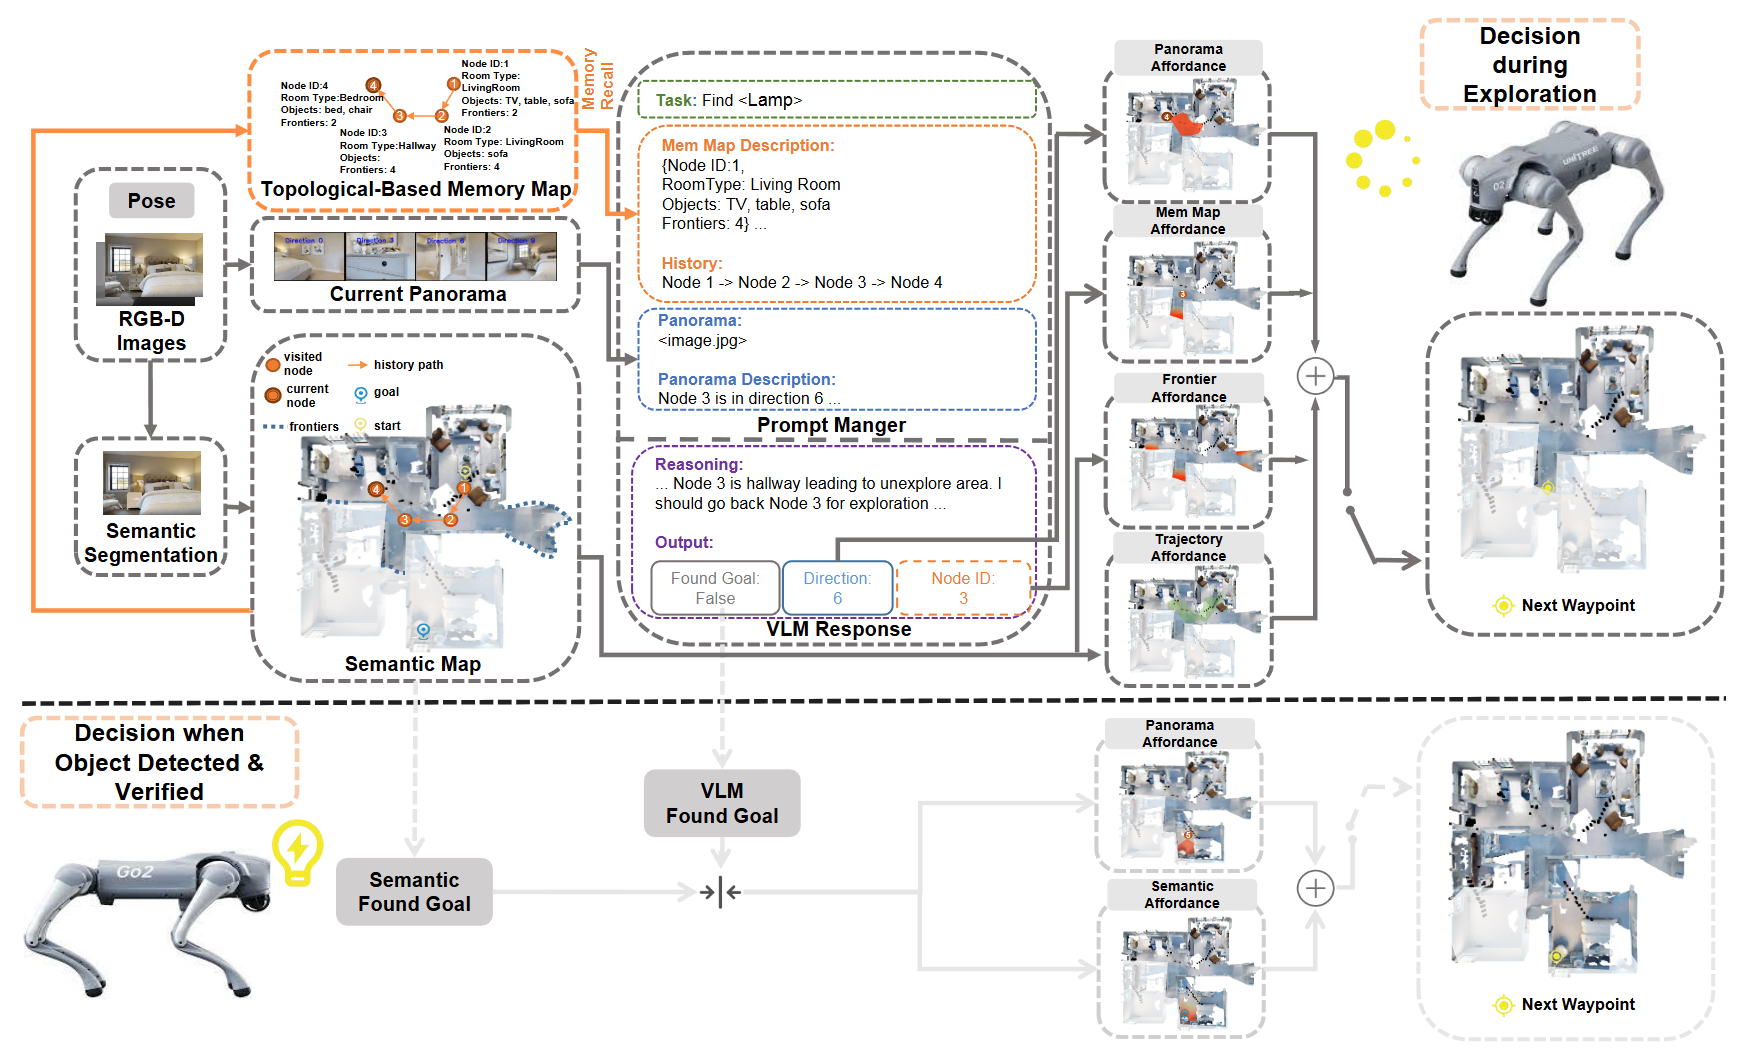
SSTG-Nav system overview
📝 AAAI 2027 🔓 Under Review
SSTG-Nav: Metric-Grounded Spatial-Semantic Topological Graphs for Reusable Object Navigation
Daojie Peng, Bingtao Wang, Jun Ma
CoRL
📝 CoRL 2026 🔓 Under Review
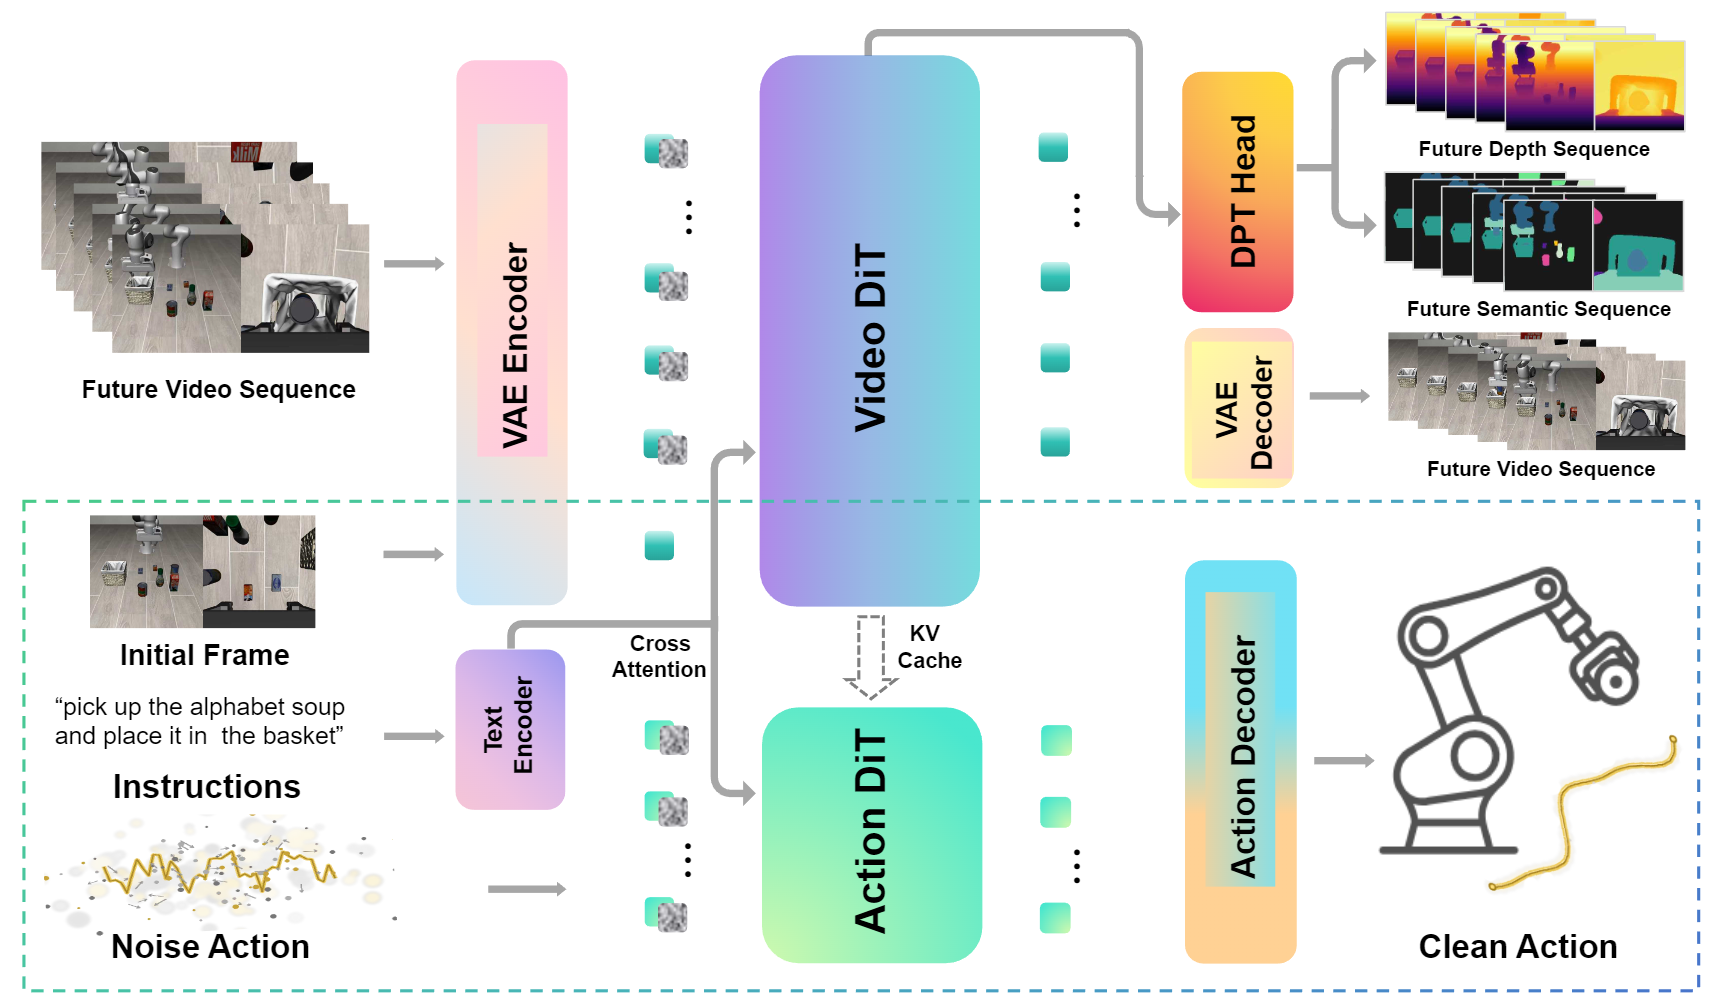
GeoSem-WAM: Geometry- and Semantic-Aware World Action Models
Fulong Ma*, Daojie Peng*, Wenjun Yue, Jiahang Cao, Bintao Wang, Qiang Zhang, Jun Ma
NeurIPS
📝 NeurIPS 2026 🔓 Under Review
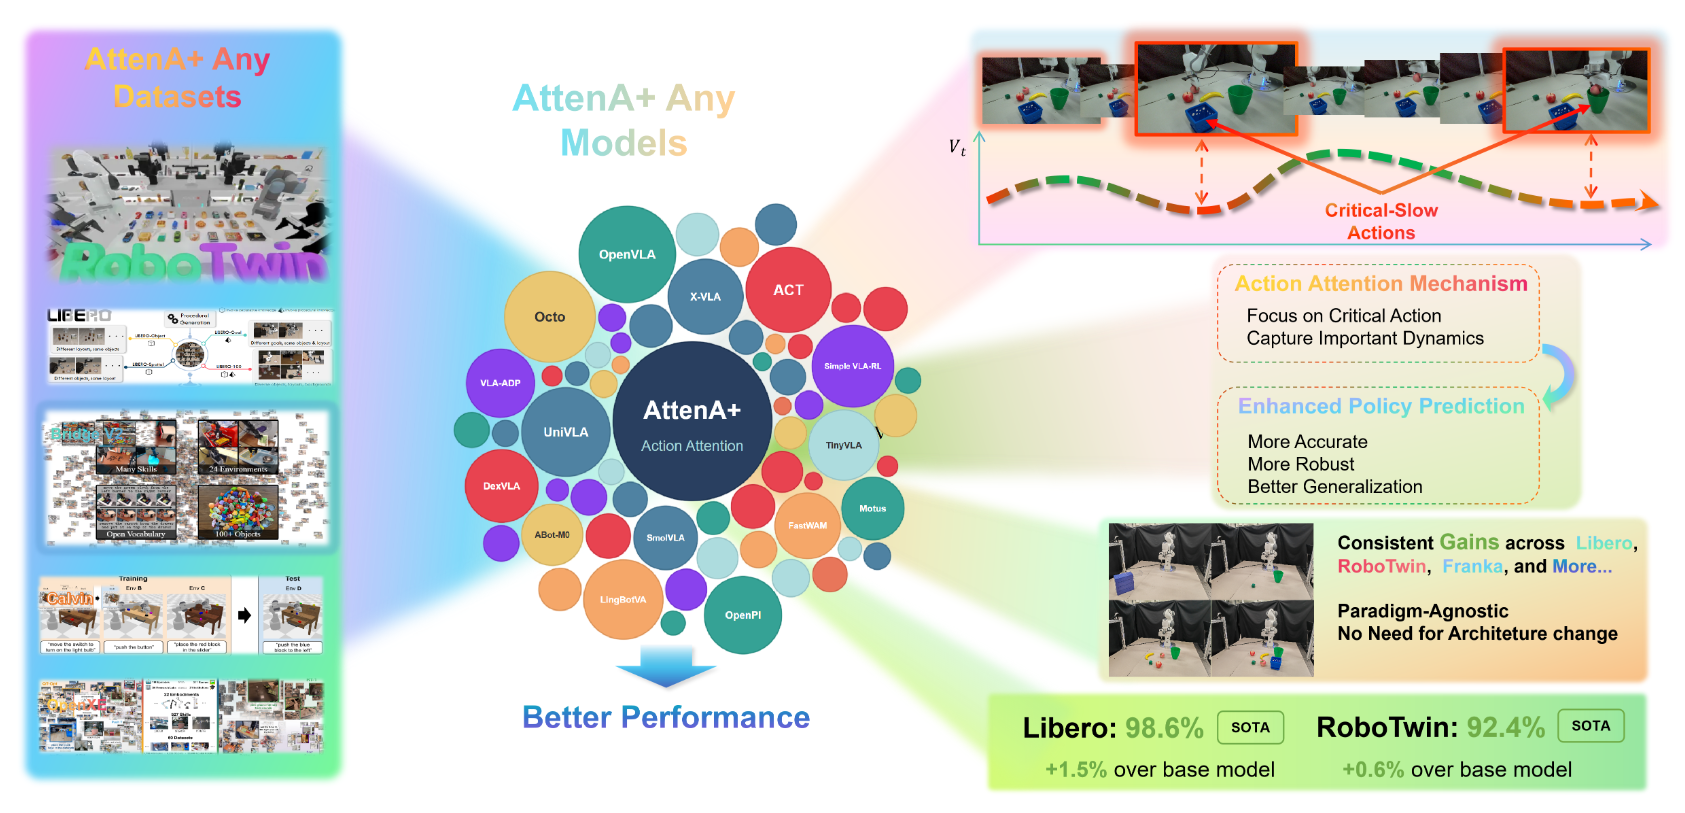
AttenA+: Rectifying Action Inequality in Robotic Foundation Models
Daojie Peng, Fulong Ma, Jiahang Cao, Qiang Zhang, Xupeng Xie, Jian Guo, Ping Luo, Andrew F. Luo, Boyu Zhou, Jun Ma
RAL
📜 RAL 2026 🔓 Under Review
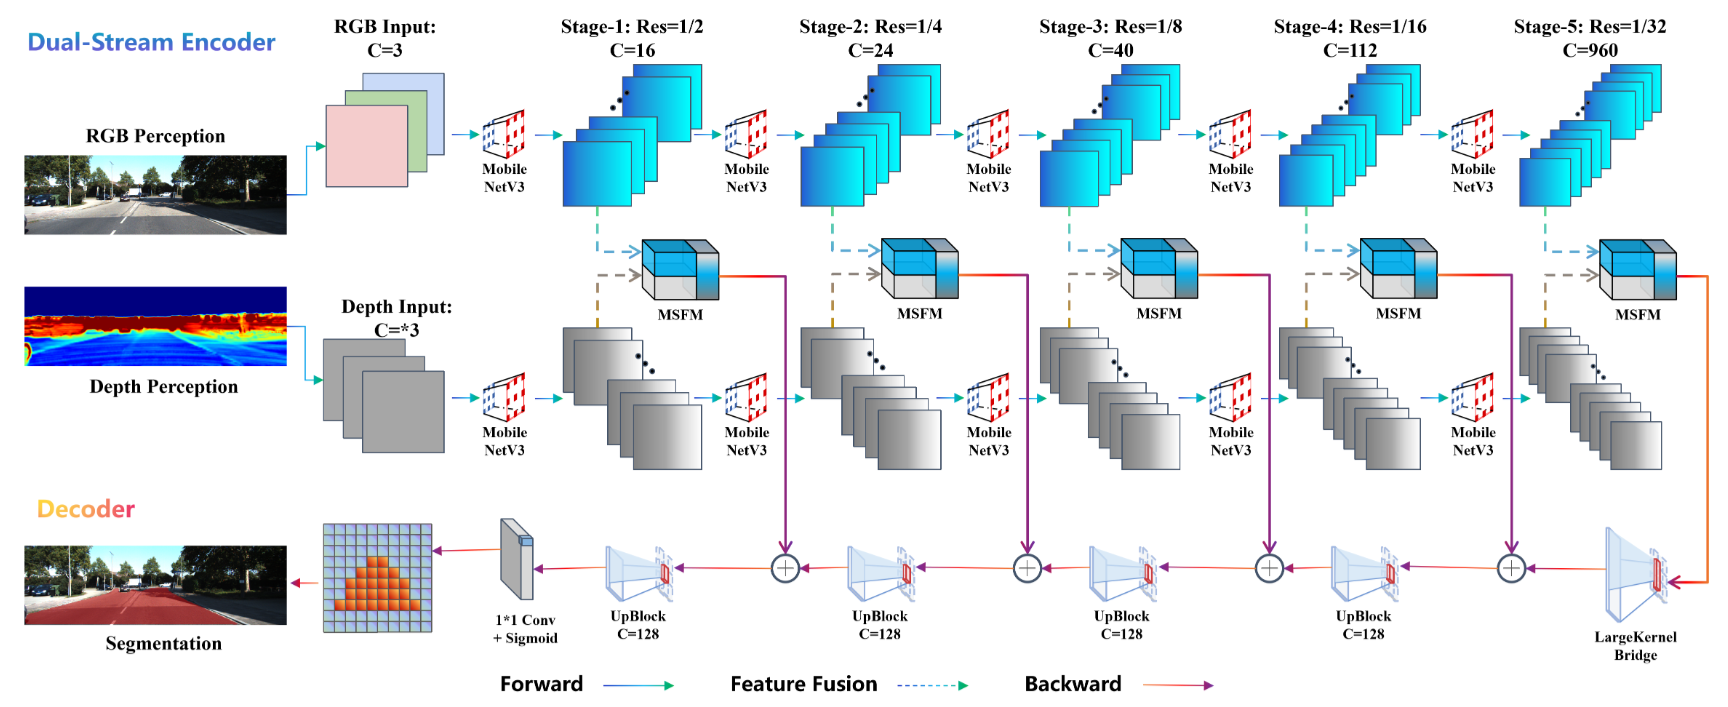
LiteViLNet: Lightweight Vision-LiDAR Fusion Network for Efficient Road Segmentation
Daojie Peng, Bingtao Wang, Fulong Ma, Liang Zhang, Jun Ma
RAL
📜 RAL 2026 ✅ Published
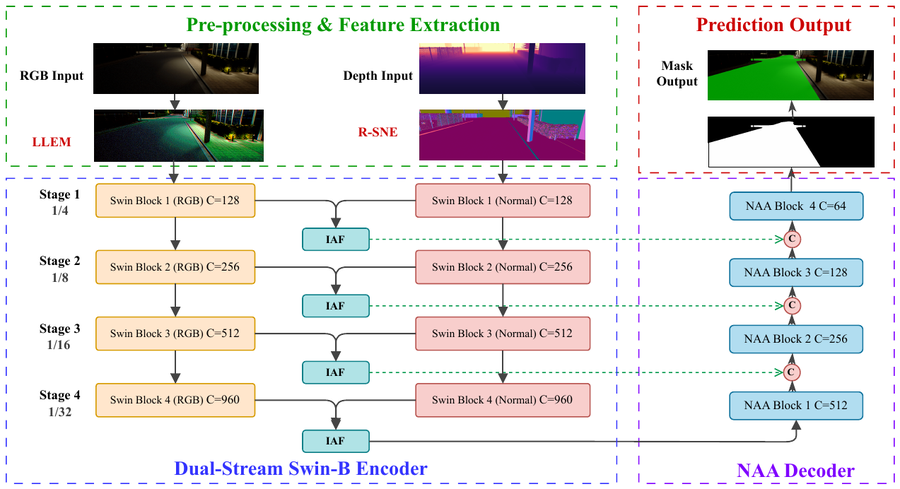
IAF-Net: Illumination-Adaptive Fusion for Low-Light Urban Road Segmentation
Bingtao Wang, Daojie Peng, Fulong Ma, Jun Ma, Liang Zhang
RAL
📜 RAL 2026 🔓 Under Review
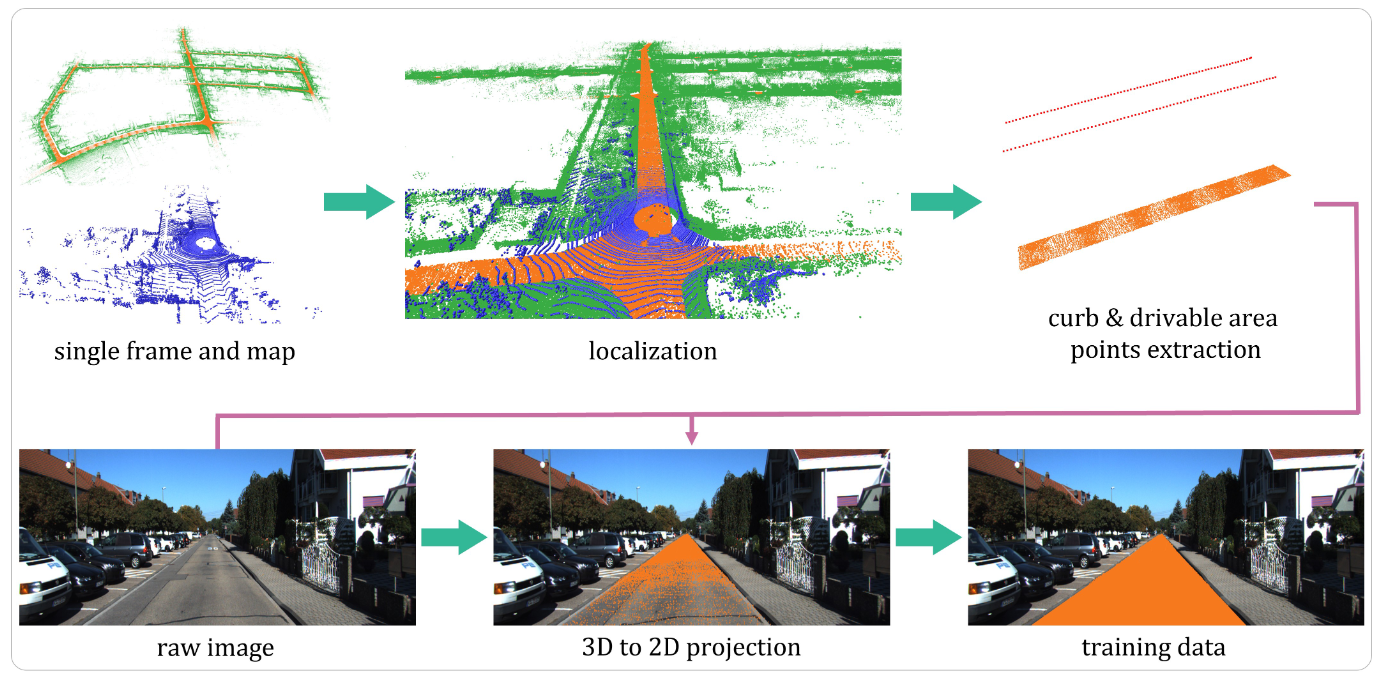
Annotation-Free Detection of Drivable Areas and Curbs Leveraging LiDAR Point Cloud Maps
Fulong Ma, Daojie Peng, Jun Ma
AAAI
📝 AAAI 2027 🔓 Under Review
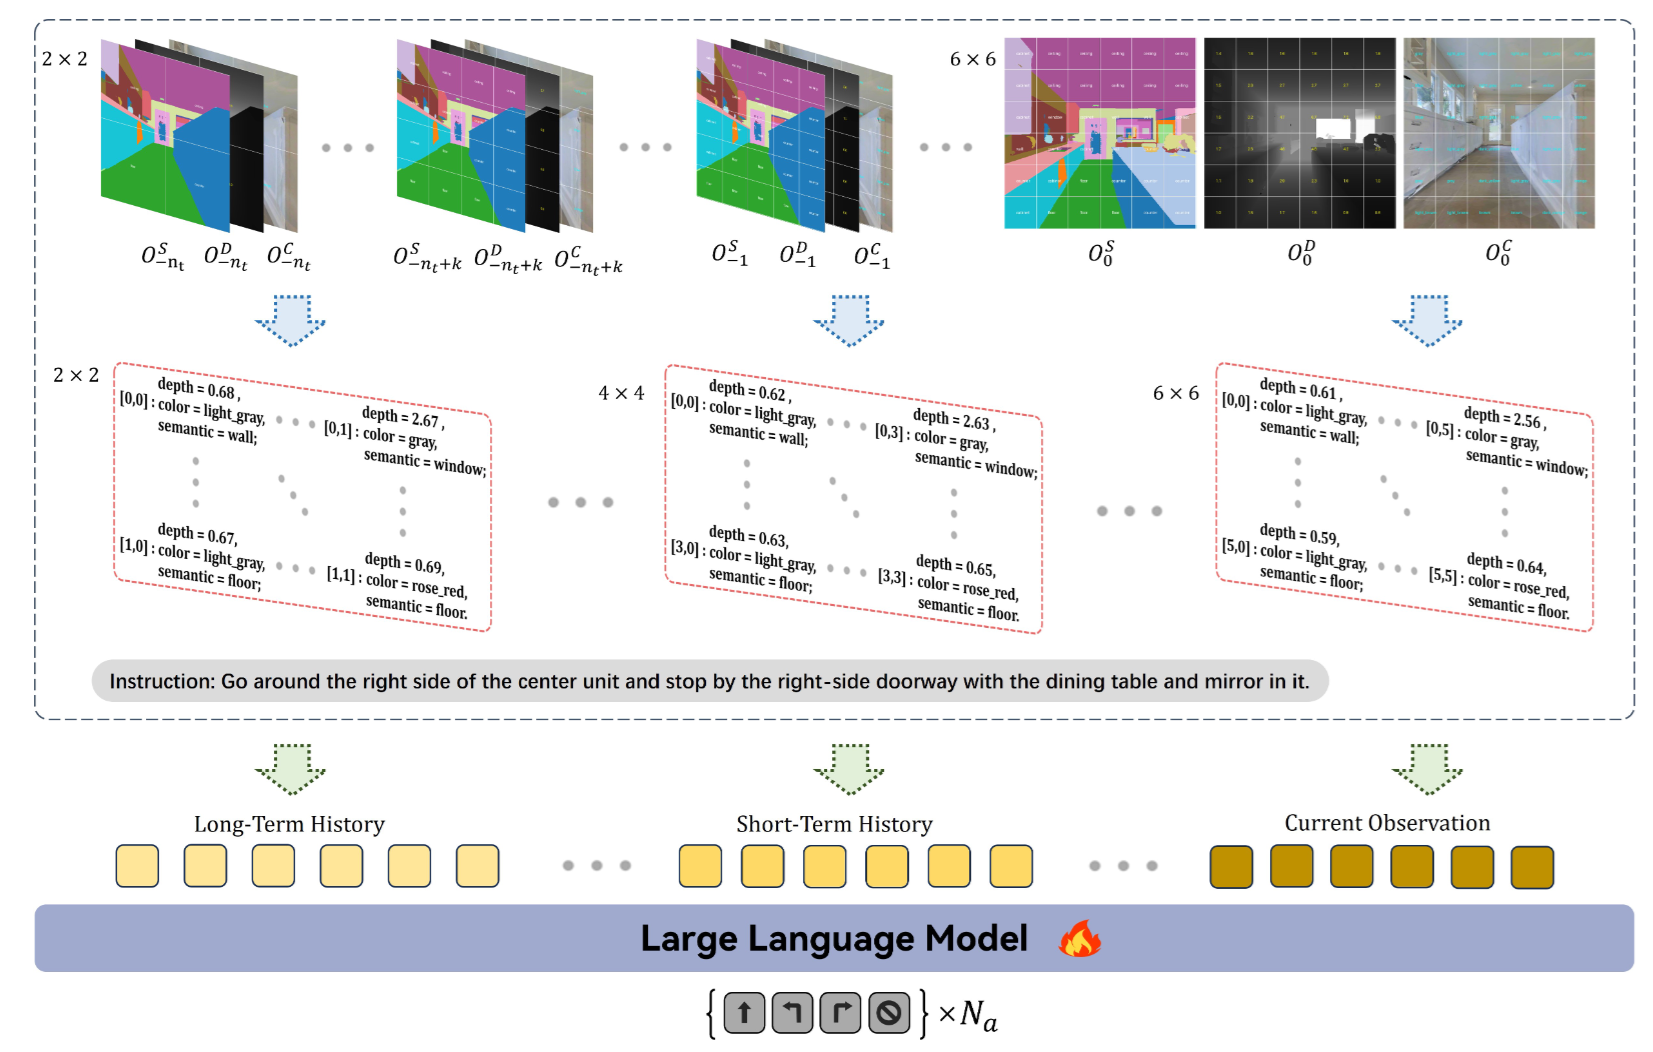
Structured Observation Language for Efficient and Generalizable Vision-Language Navigation
Daojie Peng, Fulong Ma, Jun Ma
ICRA
📝 ICRA 2025 ✅ Published
TopoNav: Topological Graphs as a Key Enabler for Advanced Object Navigation
Peiran Liu*, Qiang Zhang*, Daojie Peng*, Lingfeng Zhang*, Yihao Qin, Hang Zhou, Jun Ma, Renjing Xu, Yiding Ji
TMECH
📜 TMECH 2025 ✅ Published
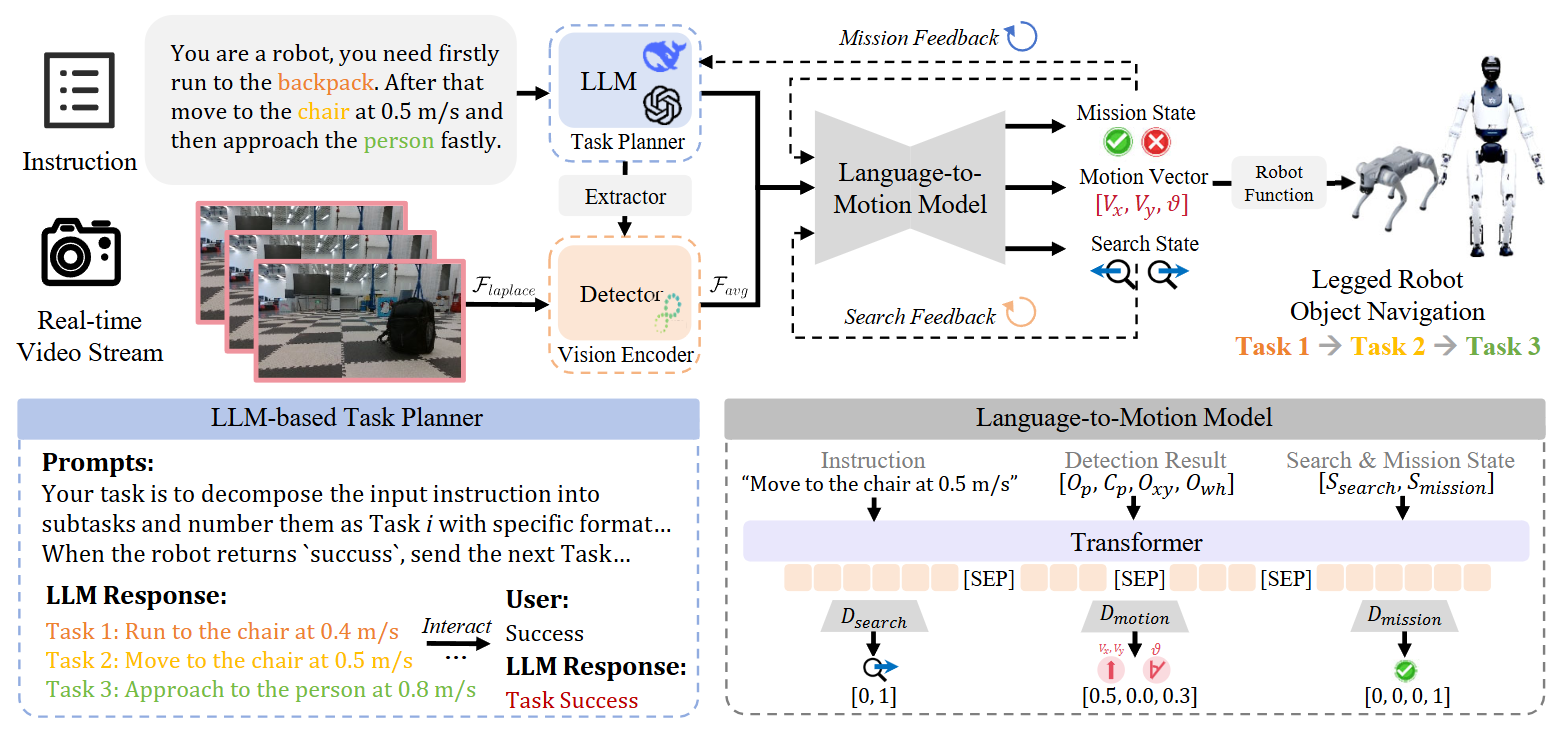
LOVON: Legged Open-Vocabulary Object Navigator
Daojie Peng, Jiahang Cao, Qiang Zhang, Jun Ma

📜 Patents

Invention
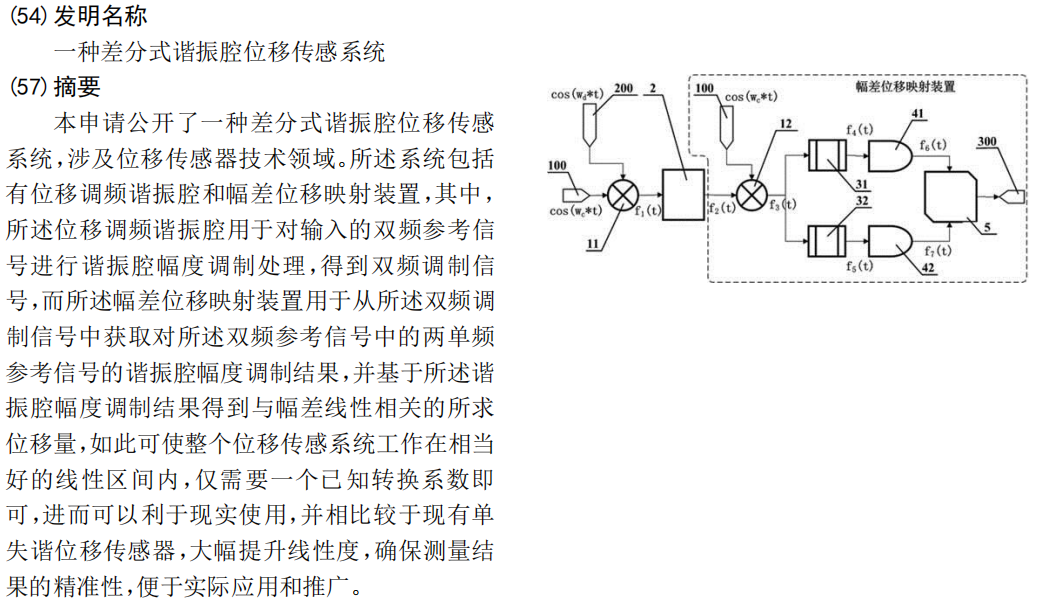
Differential Resonant Cavity Displacement Sensing System
App No.:202310108732.1 | Pub No.:CN115824026A
Daojie Peng
1st Inventor Invention Patent
Invention
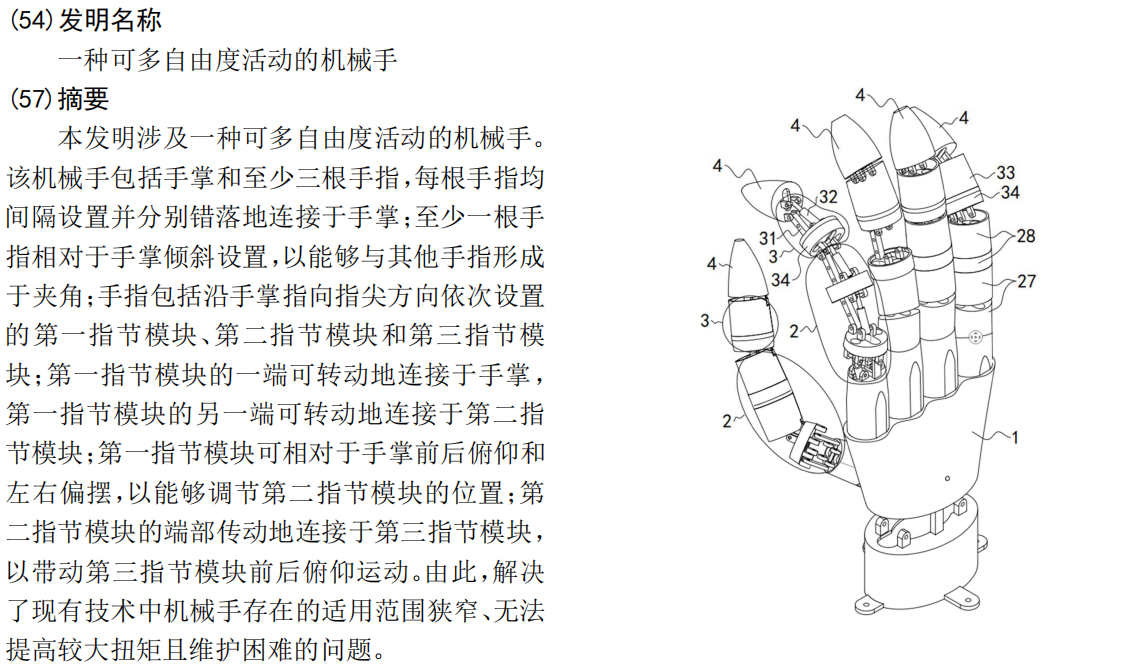
Multi-Degree-of-Freedom (Multi-DOF) Robotic Manipulator
App No.:202310229097.2 | Pub No.:CN116214555A
Daojie Peng
1st Inventor Invention Patent
Invention
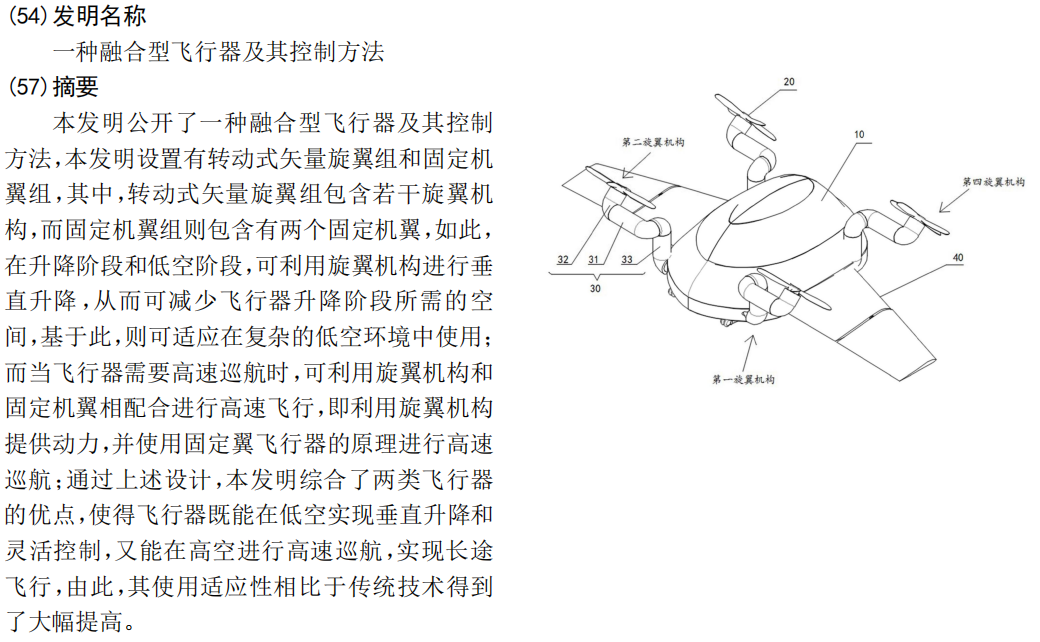
Hybrid Aircraft and Its Control Method
App No.:202310808122.2 | Pub No.:CN116834949A
Daojie Peng
1st Inventor Invention Patent
Invention
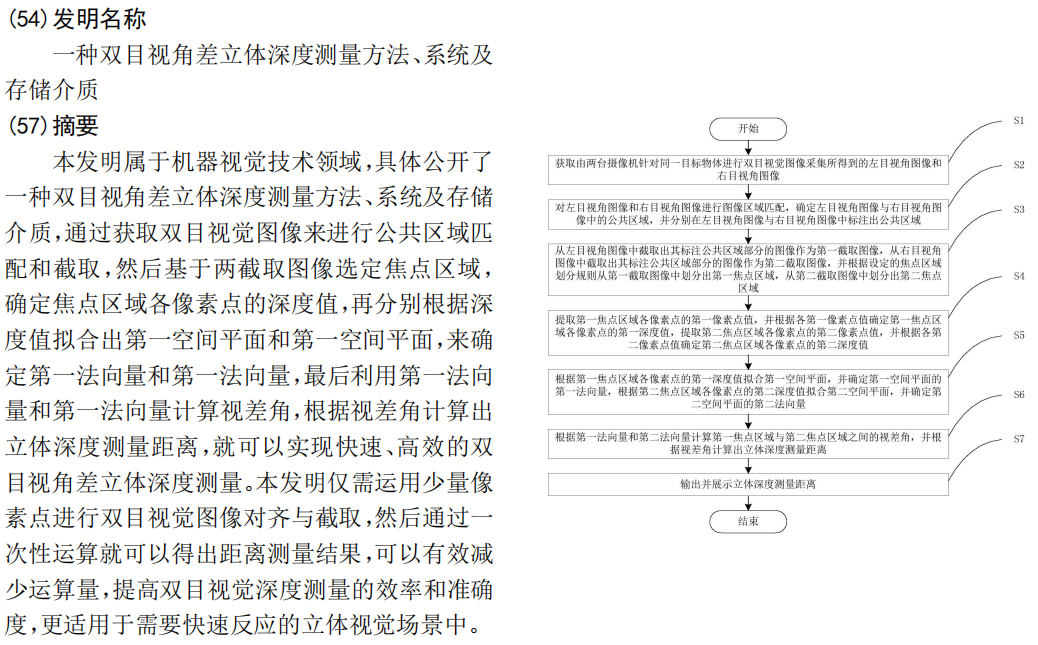
Binocular Disparity-based Stereo Depth Measurement Method, System, and Storage Medium
App No.:202310916798.3 | Pub No.:CN116929290A
Daojie Peng
1st Inventor Invention Patent
Utility
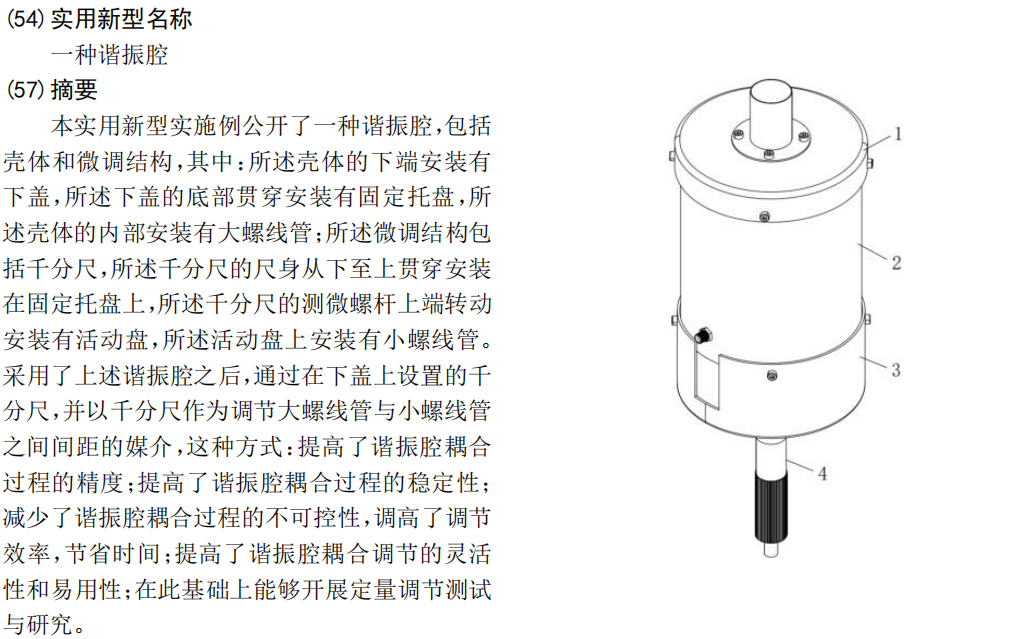
Resonant Cavity
App No.:202222817815.1 | Pub No.:CN218498352U
Daojie Peng
1st Inventor Utility Model
Utility
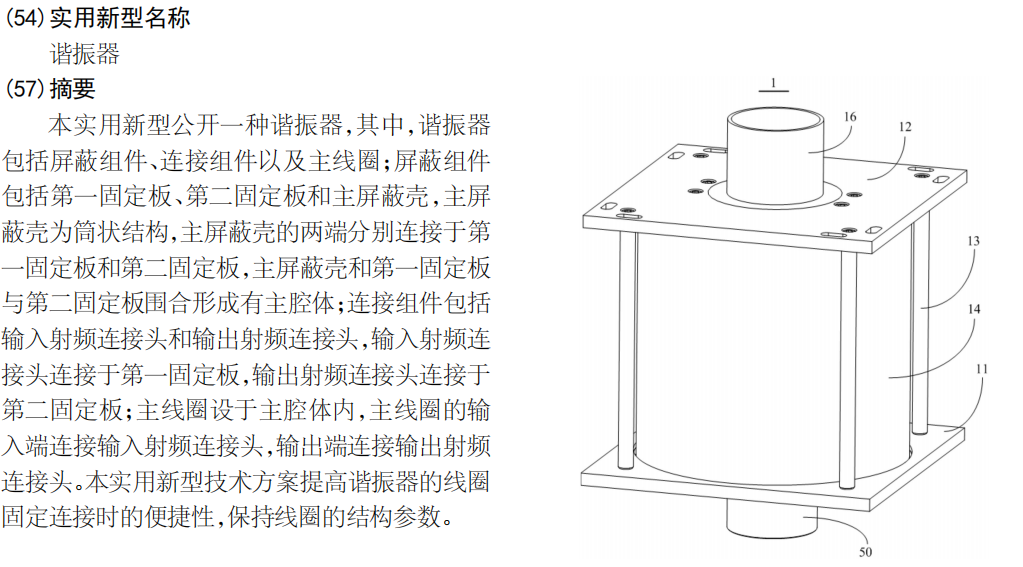
Resonator
App No.:202321801161.1 | Pub No.:CN220253443U
Yao Lu, Daojie Peng
2nd Inventor Utility Model

🎓 Education

Hong Kong University of Science and Technology (Guangzhou) 2025 – Present
PhD Student, Robotics and Autonomous Systems
Southern University of Science and Technology 2021 – 2024
Master’s Degree, Electronic Science and Technology
Shandong University 2017 – 2021
Bachelor’s Degree, Communication Engineering